- Supervisor: Prof. Rui Huang
- Research Assistant, Shenzhen Institute of Artificial Intelligence and Robotics (Jun. 2024 – Present)
Kai Ye
M.Phil, Computer & Information Engineering
The Chinese University of Hong Kong, Shenzhen
Email: kaiye1@link.cuhk.edu.cn
Scholar | GitHub | Download CV
About
I am an M.Phil student at The Chinese University of Hong Kong, Shenzhen. My research focuses on the intersection of embodied intelligence and computer vision, including dexterous manipulation and generation model. My goal is to enable everyone to have an independent robot to collaborate with, create, and live together.
Education
- Supervisor: Prof. Minqiang Yang
- Research Assistant, UAIS Lab (Sep. 2020 – Jul. 2022)
Publications
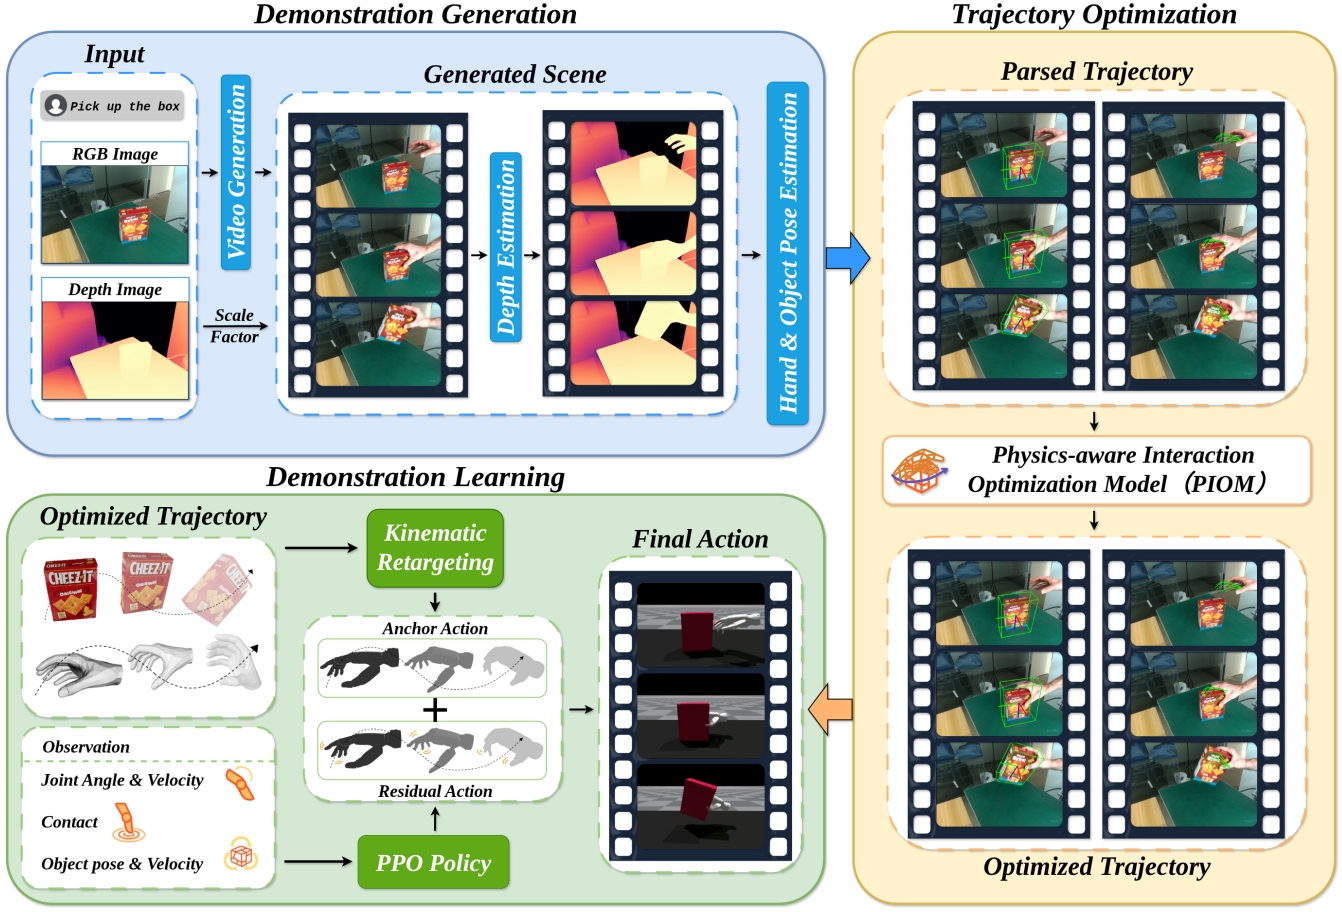
Gen2Real: Towards Demo-Free Dexterous Manipulation by Harnessing Generated Video
arXiv:2509.14178. Submitted to ICRA 2026.
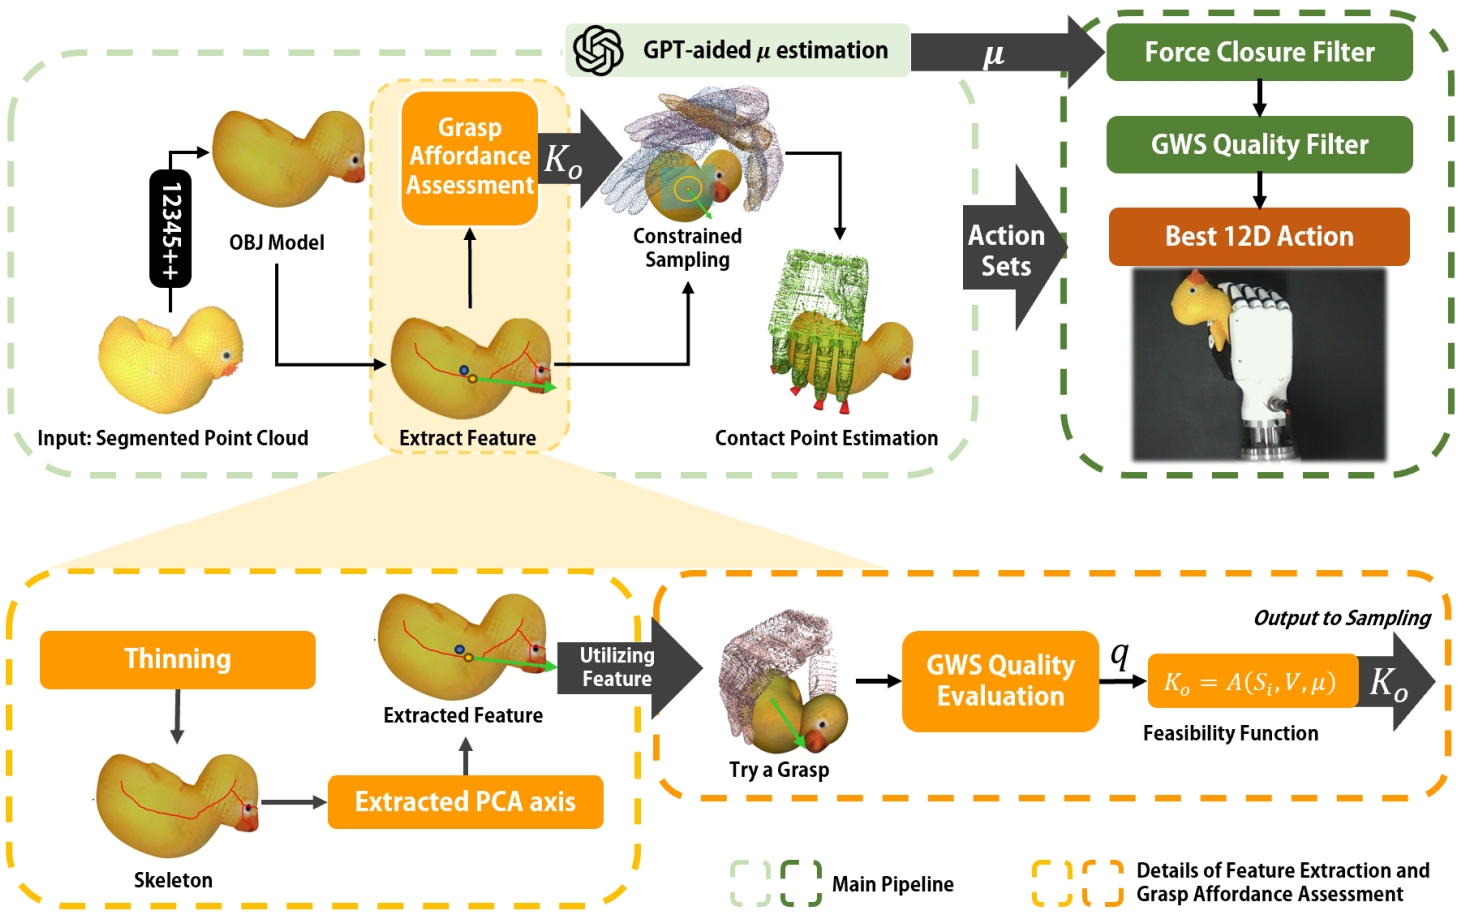
Grasp What You Want: Embodied Dexterous Grasping System Driven by Your Voice
arXiv:2412.10694. Major revision at Journal of Field Robotics (JFR).
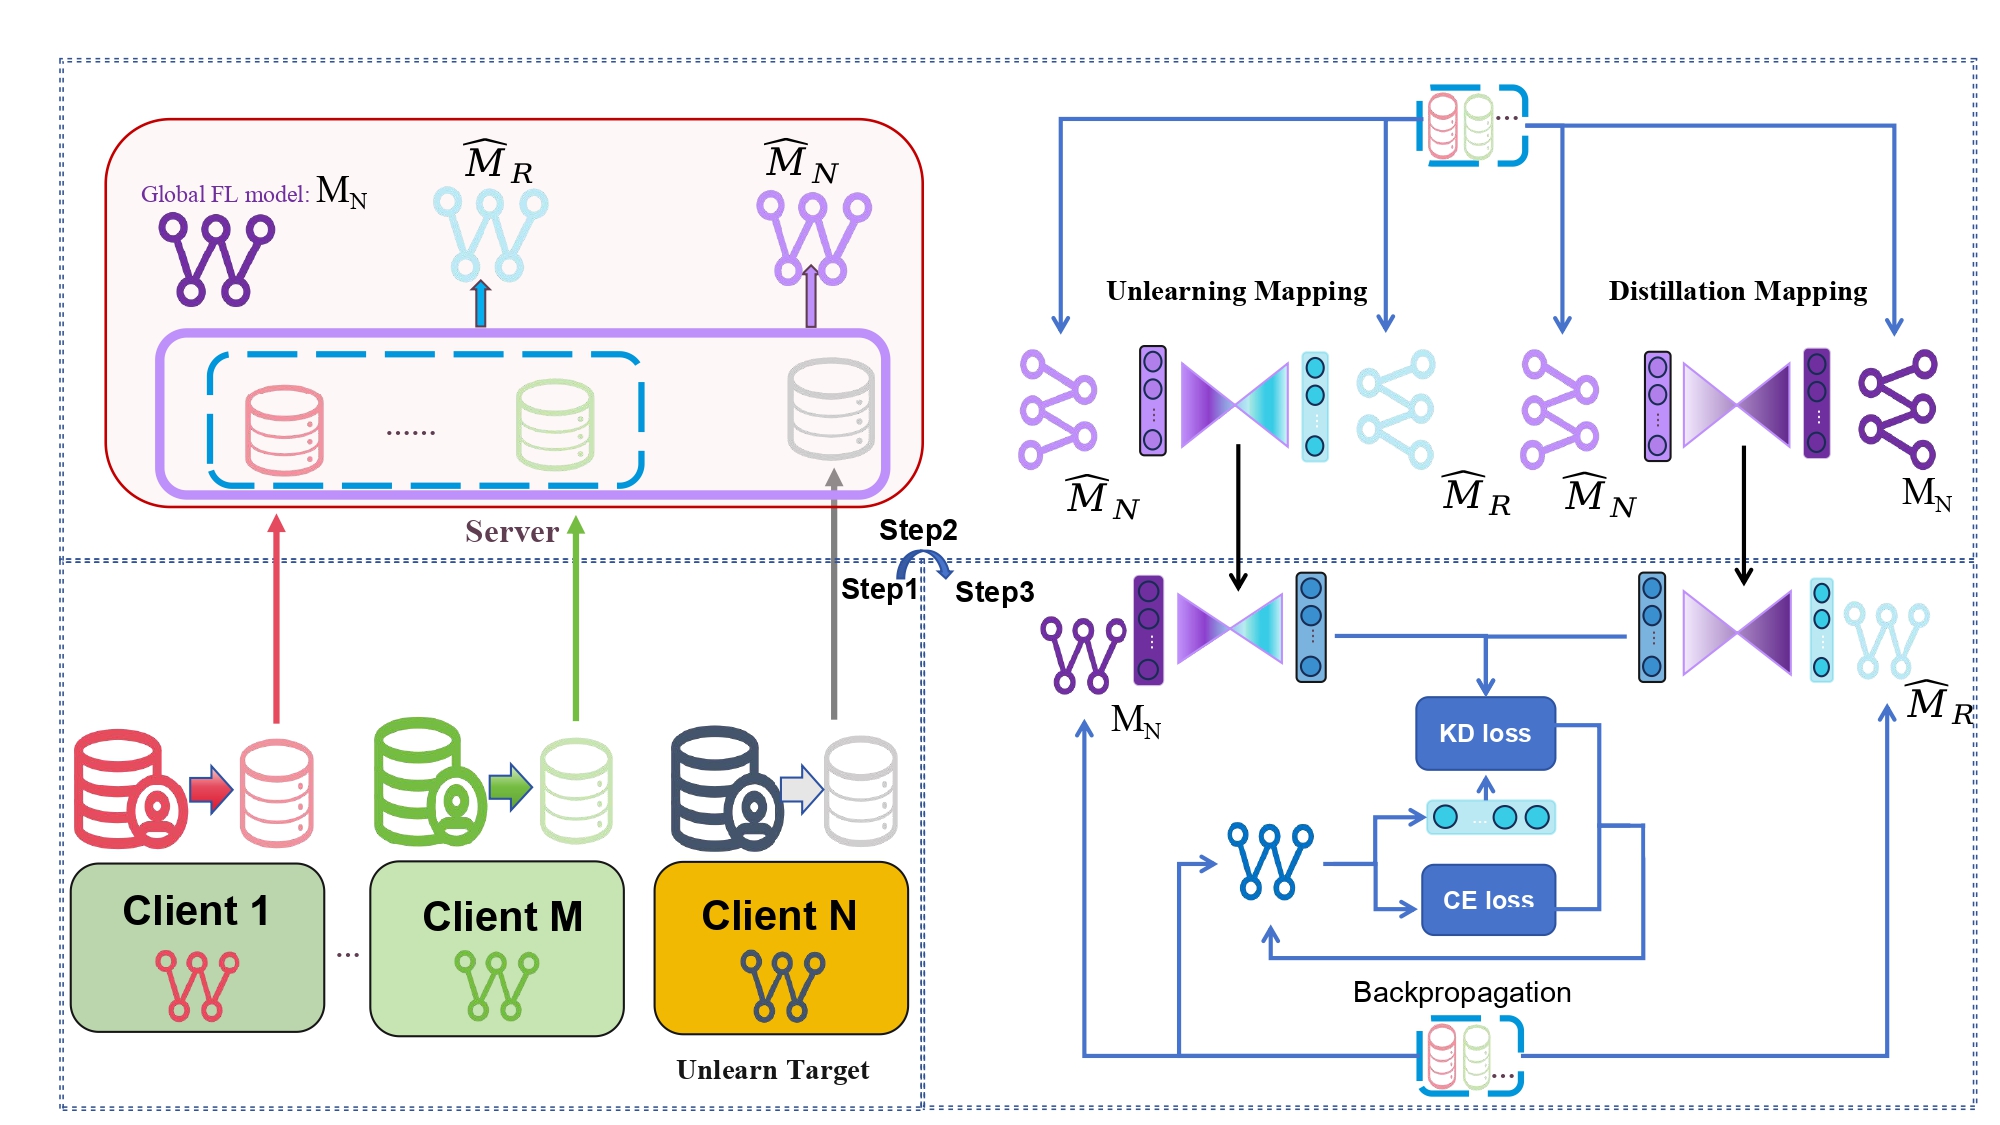
FU-Dual: Federated Unlearning via Dual Distillation
Submitted to CVPR 2026.
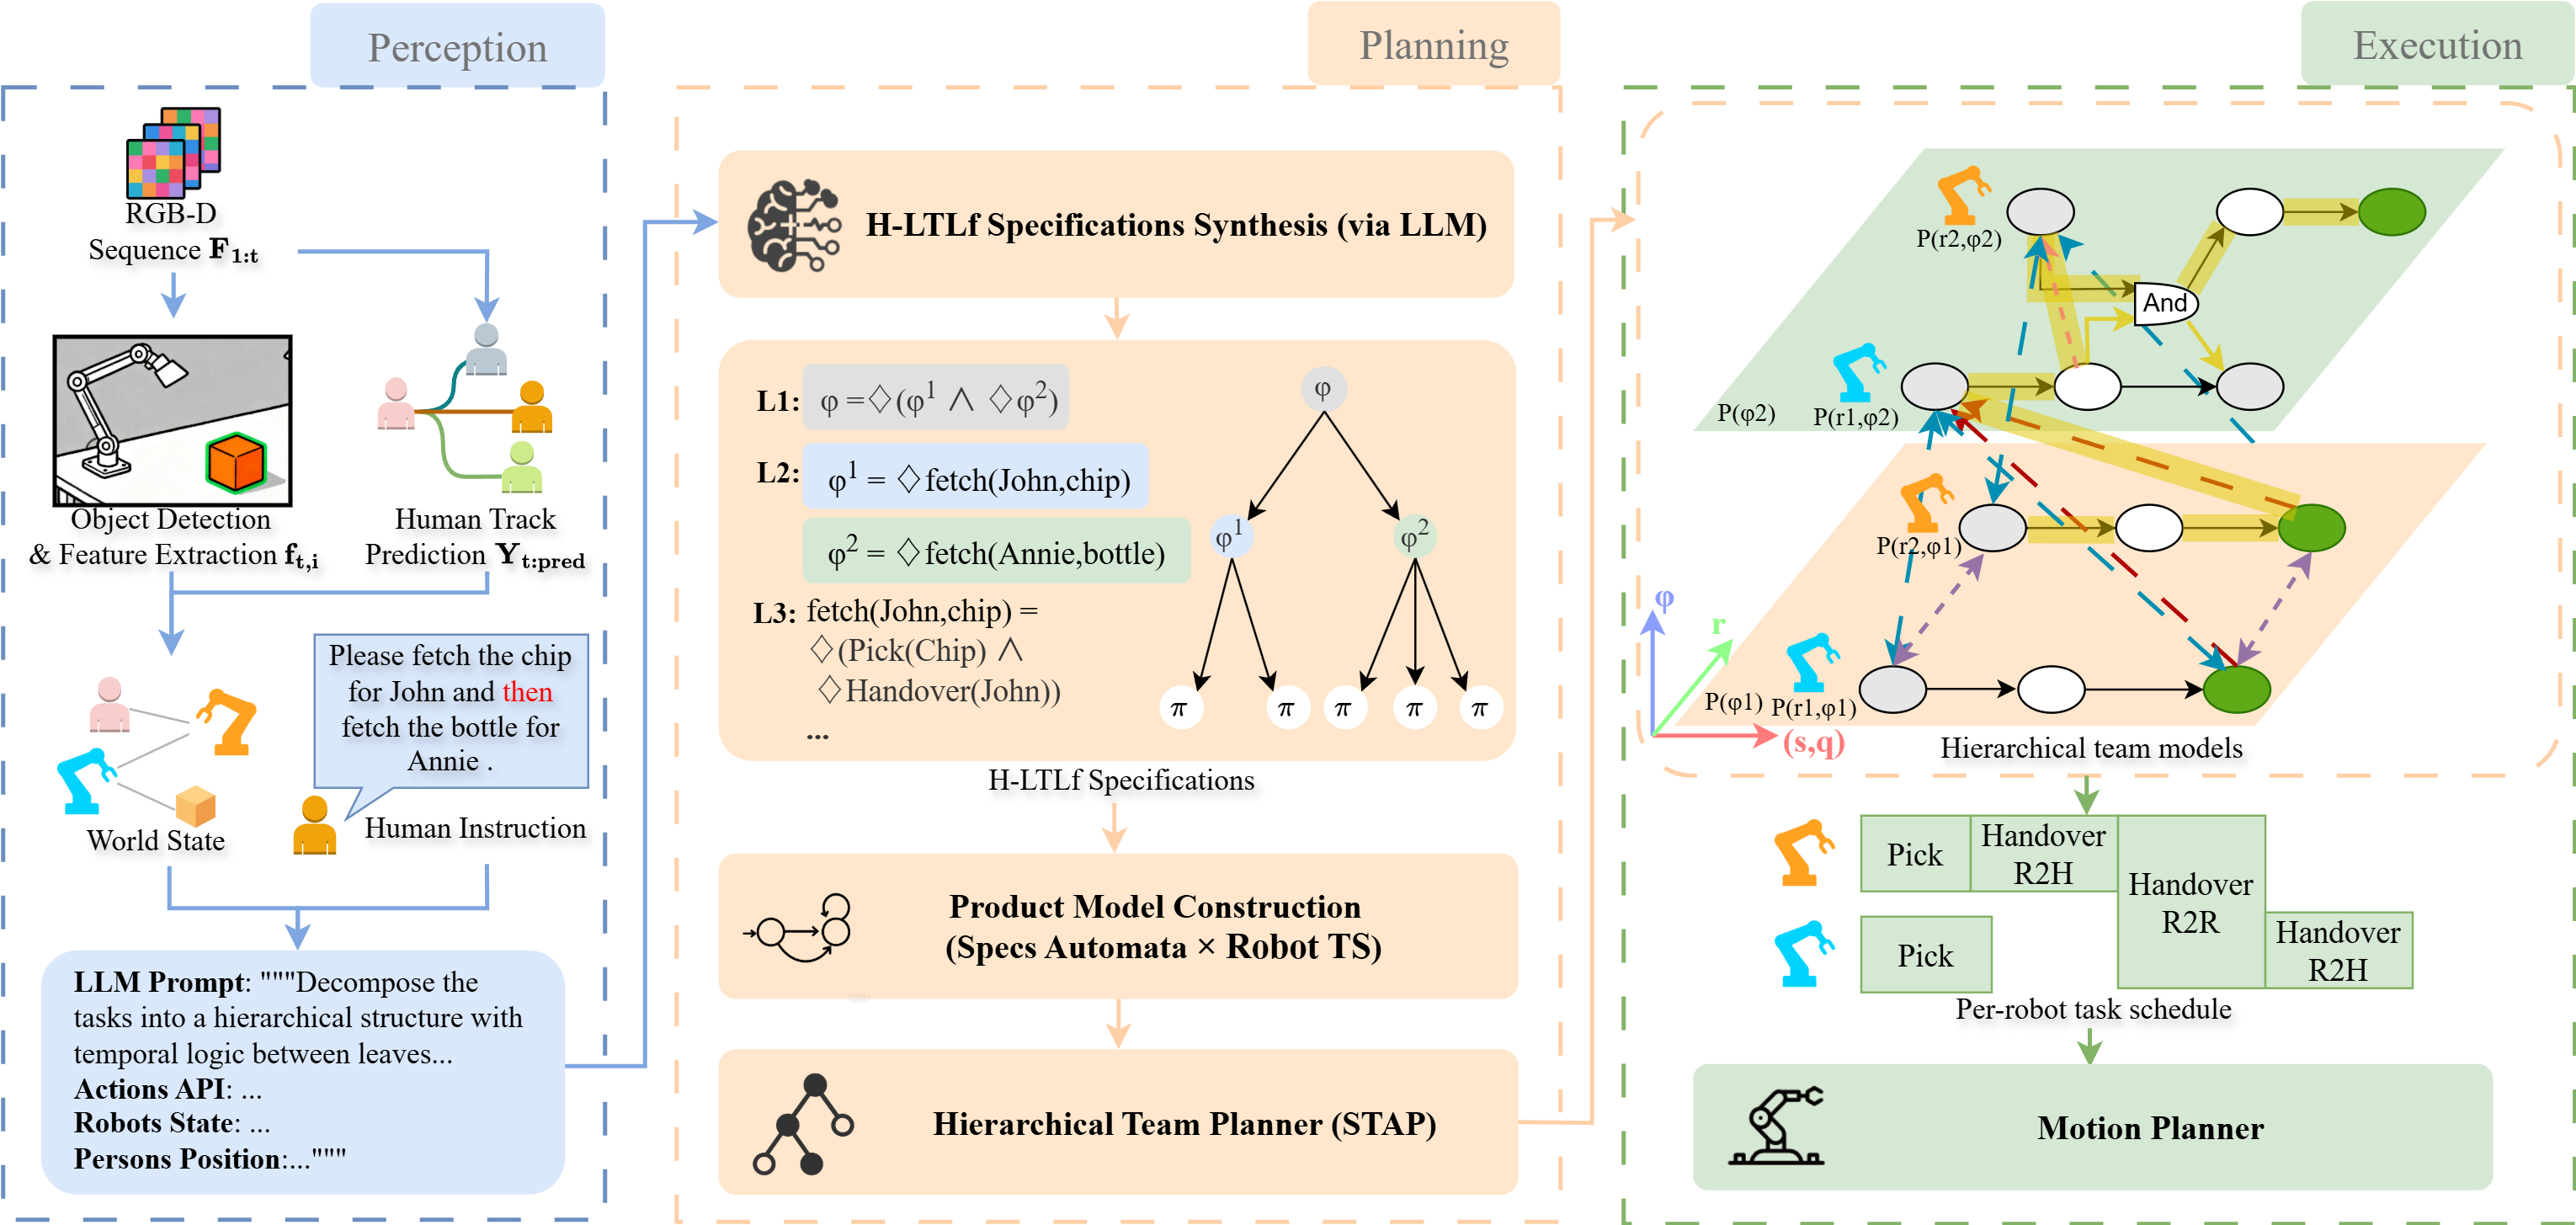
LLM-Grounded Dynamic Task Planning with Hierarchical Temporal Logic for Human-Aware Multi-Robot Collaboration
Submitted to RA-L.
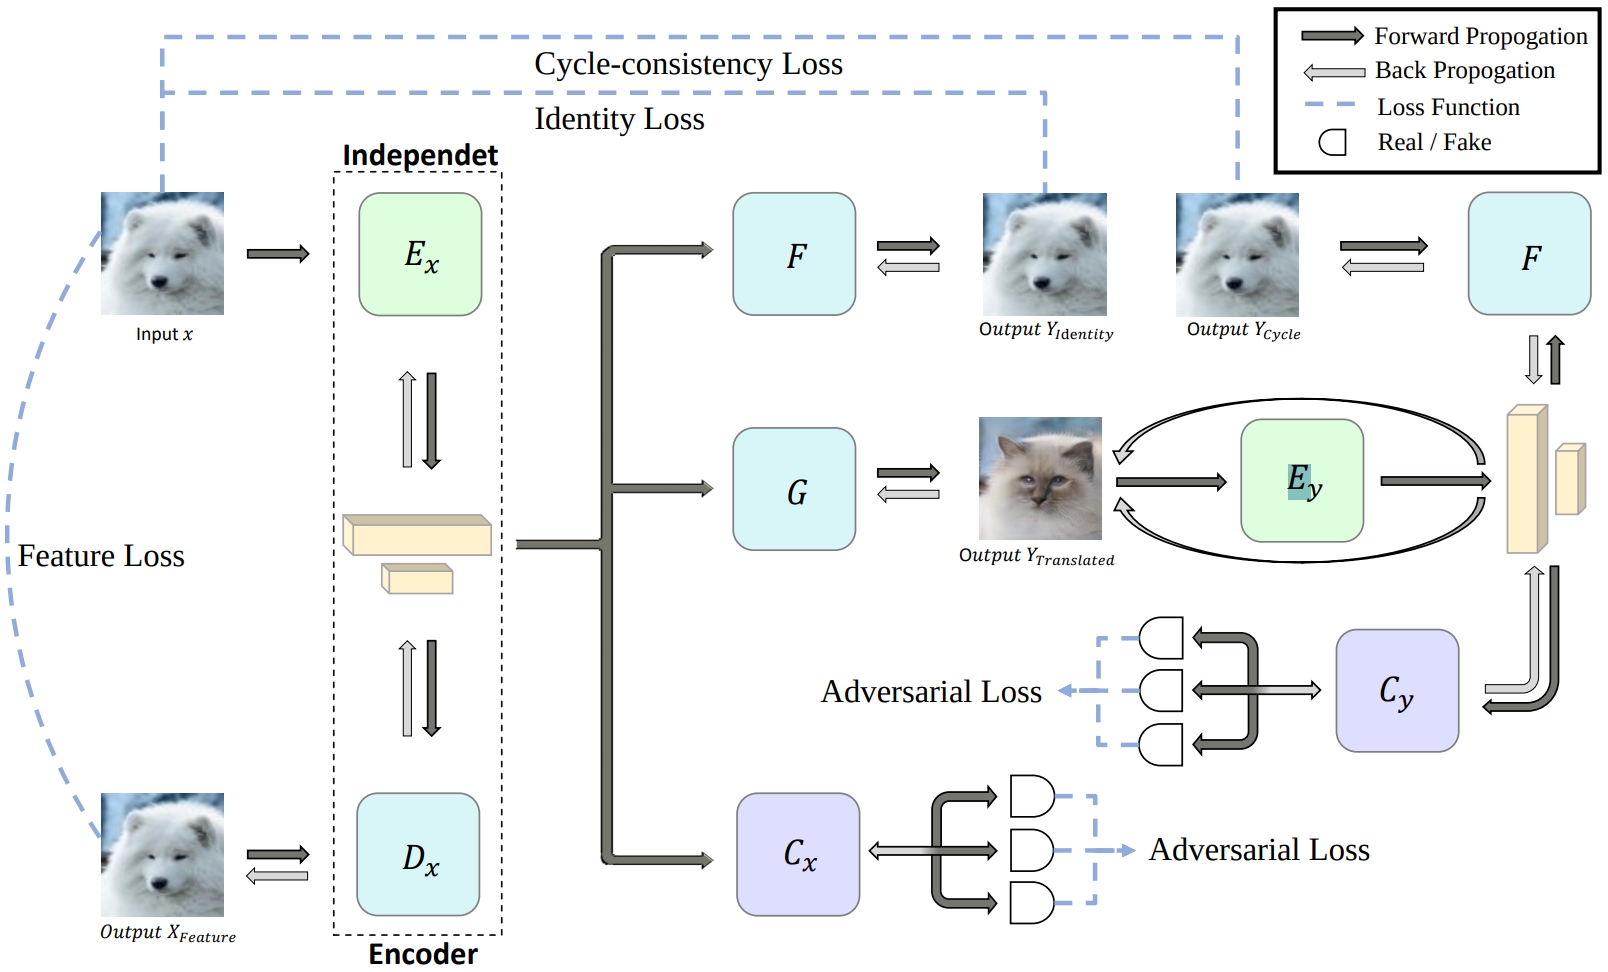
Independent Encoder for Deep Hierarchical Unsupervised Image-to-Image Translation
arXiv:2107.02494.
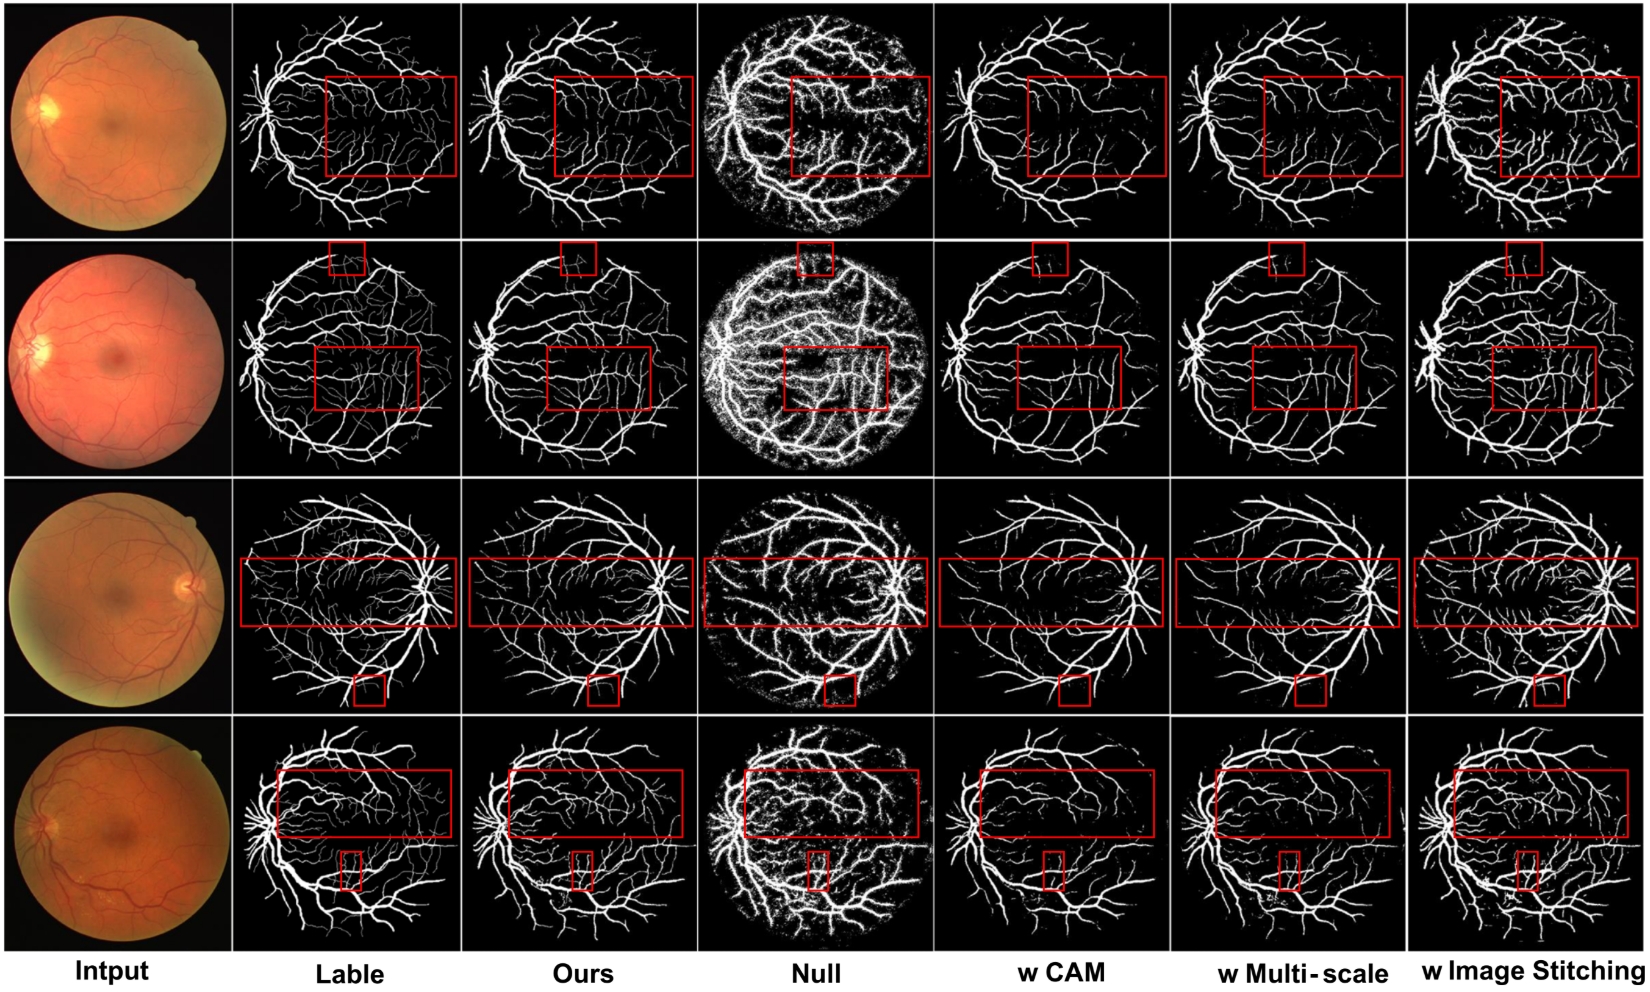
Retinal Vessel Segmentation in Medical Diagnosis using Multi-scale Attention Generative Adversarial Networks
Journal of Mobile Networks and Applications.
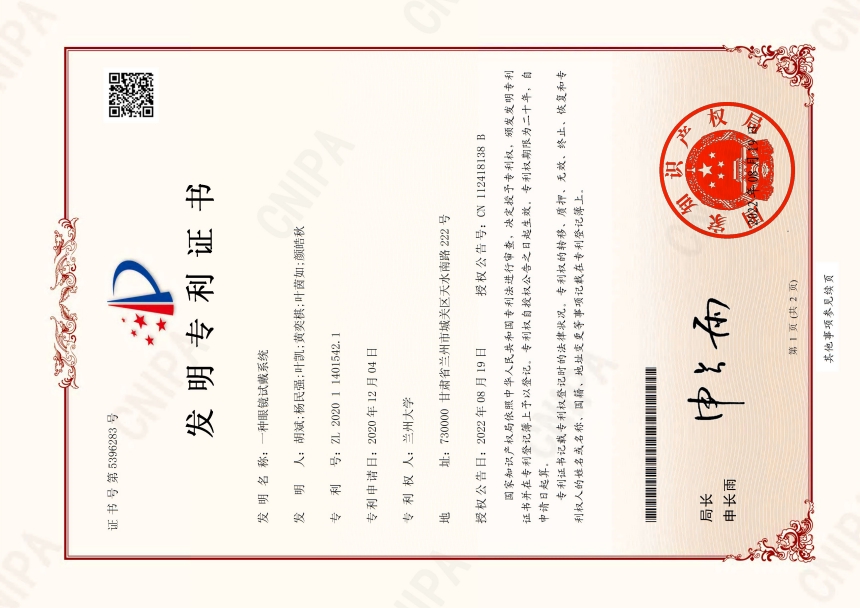
A kind of Eyeglasses Try-On System
National Invention Patent CN112418138B.
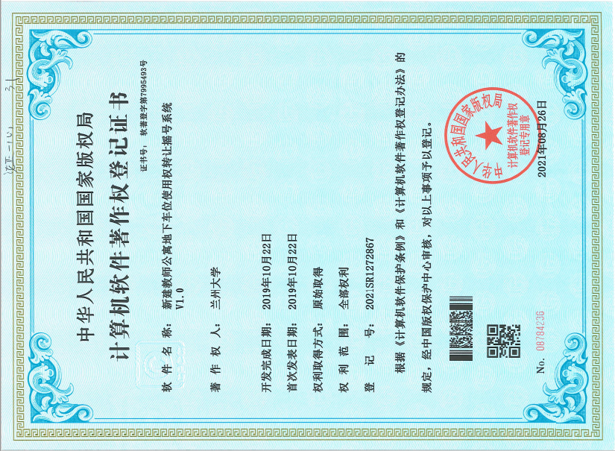
Lottery system for the right to use underground parking spaces
Software Copyright.
Work Experience
- Trajectory Prediction: Developed network architecture optimization and loss function design approaches; achieved 10% improvement over baseline and resolved 44.05% real-world road-test issues
- Mapless Driving: Data engineering for road-network structure prediction; studied data diversity/density impacts
Projects Experience
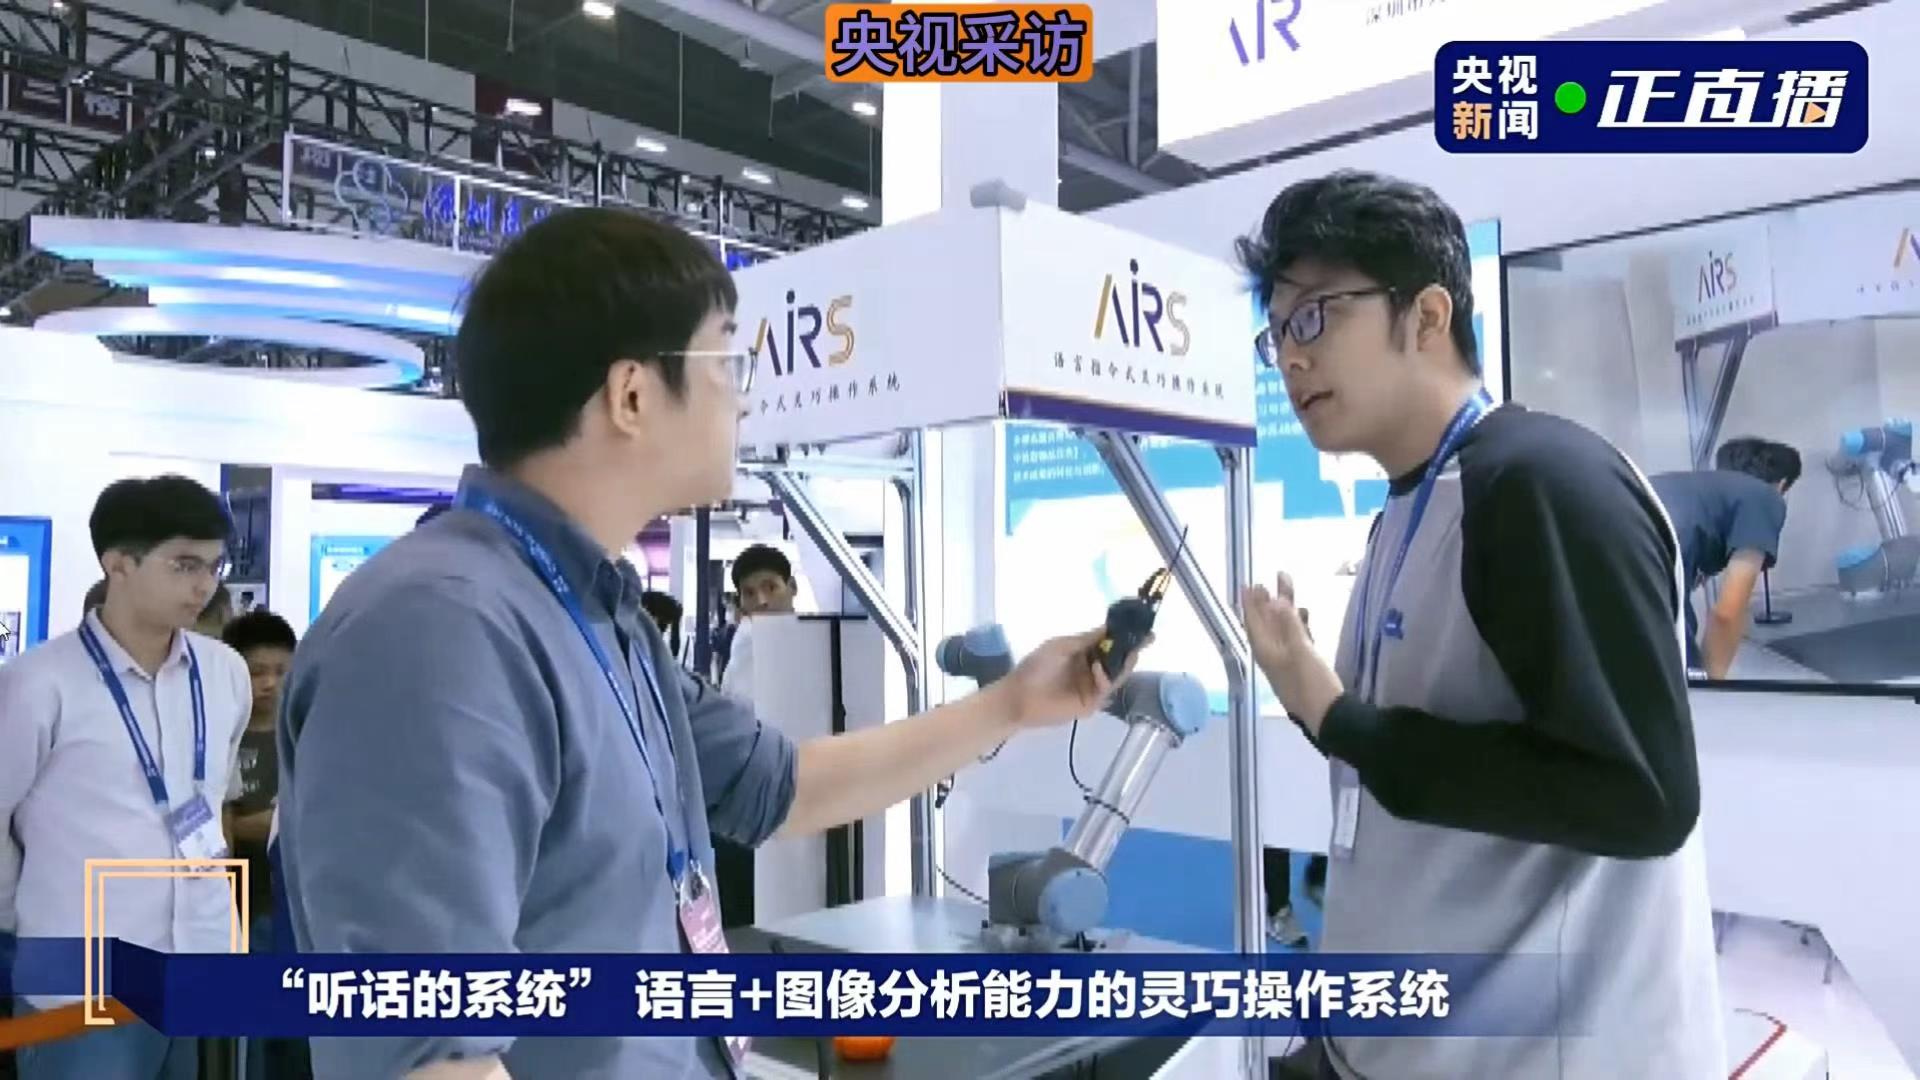
Featured on CCTV during the 2024 China International Hi-Tech Fair
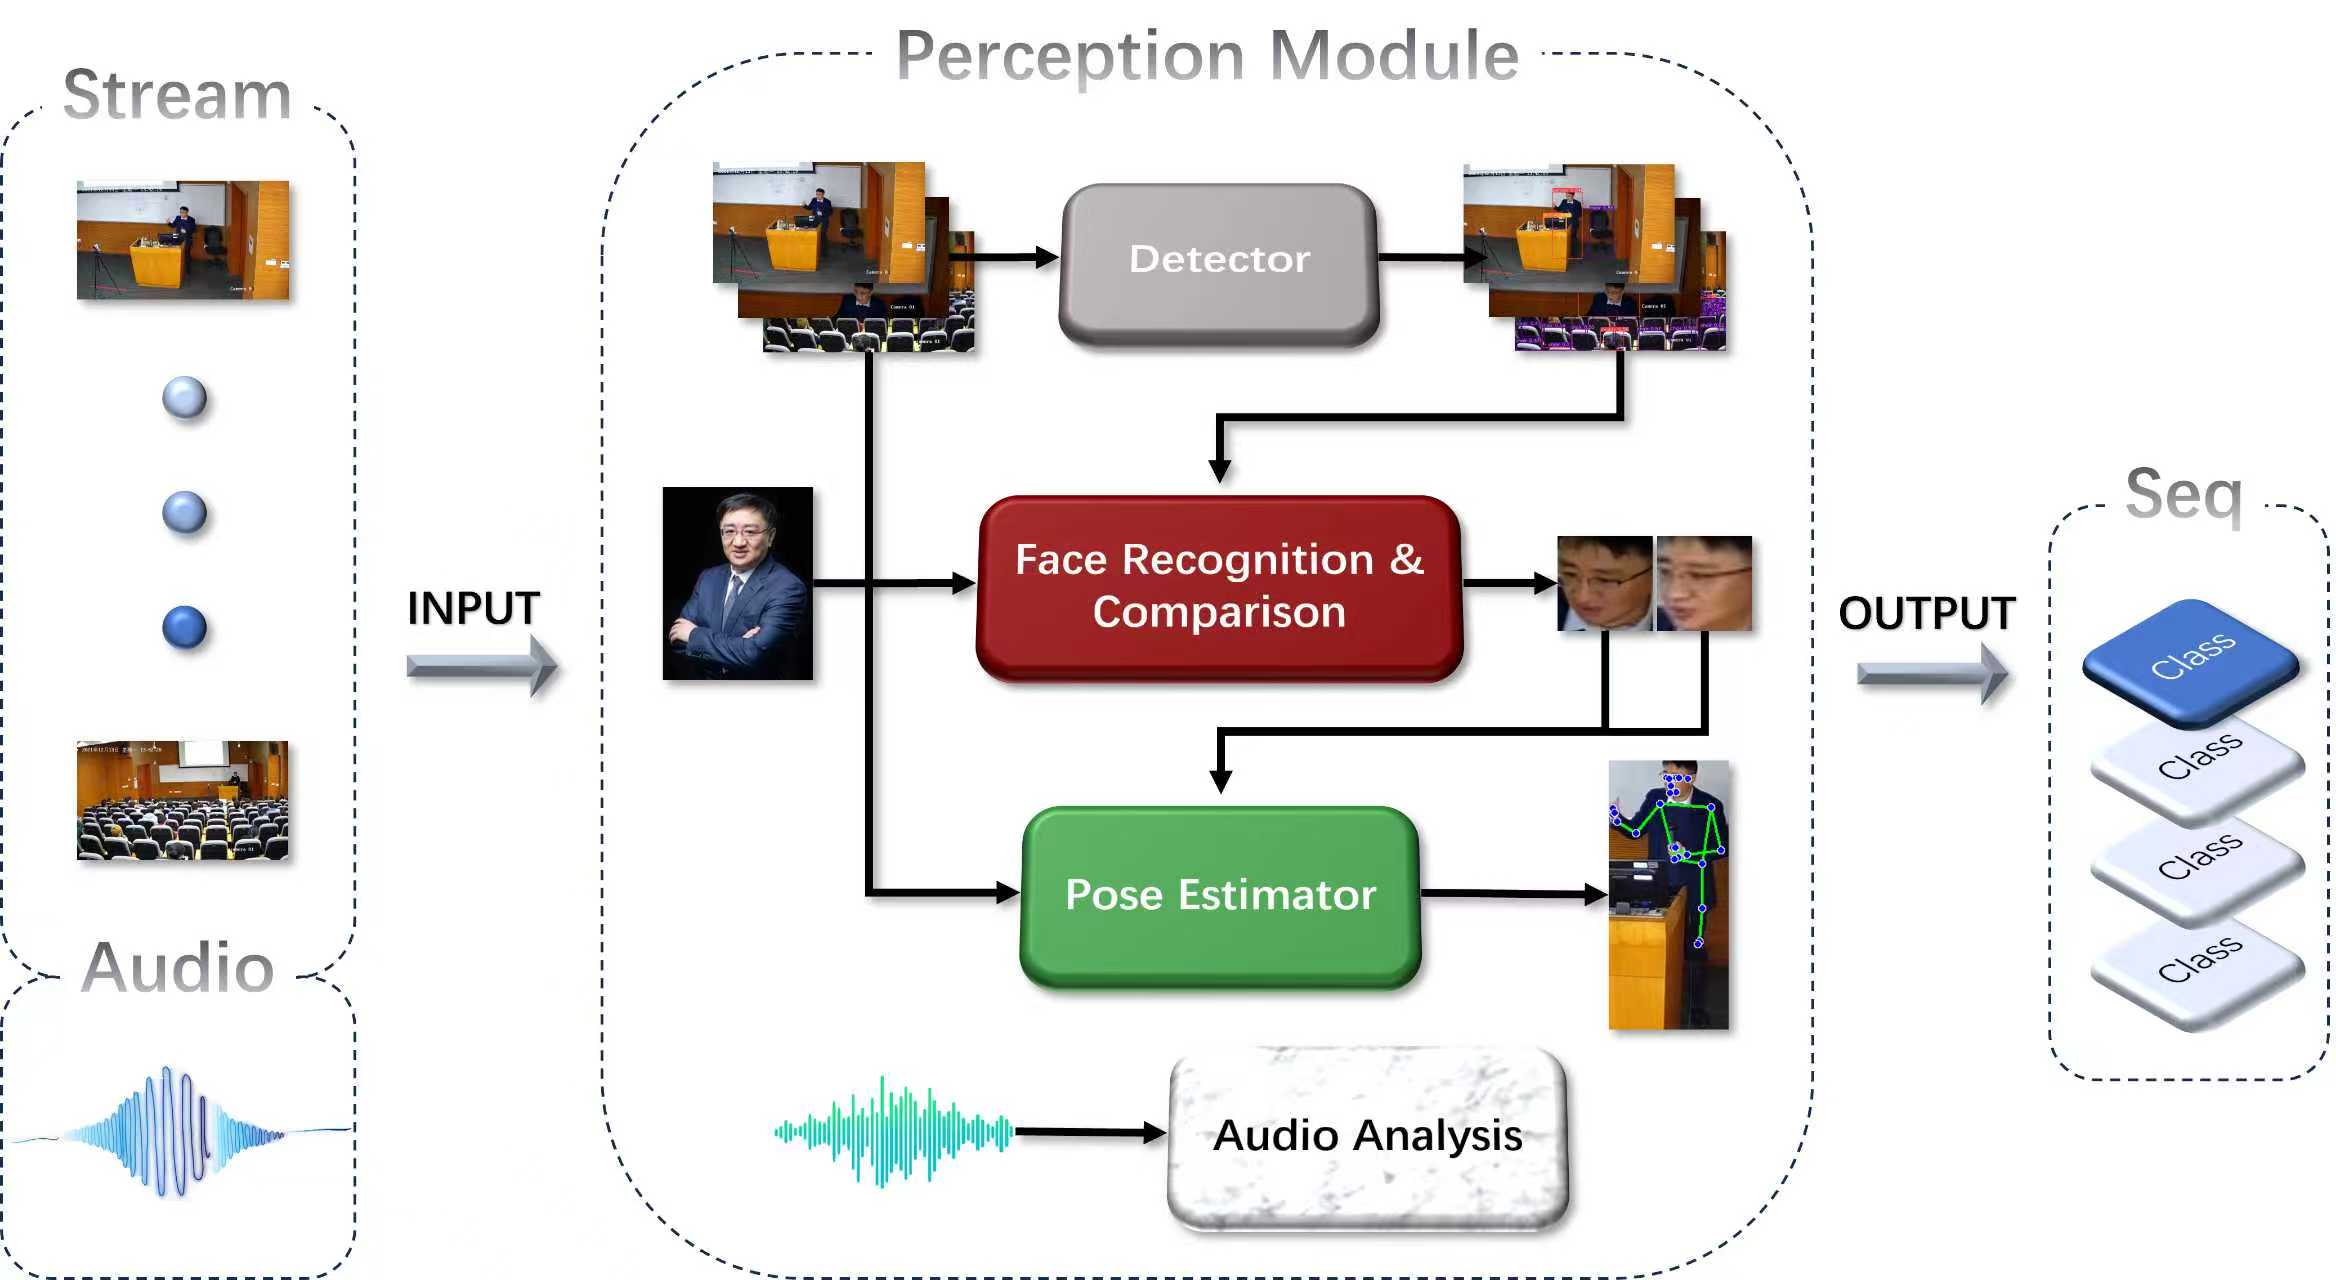
Automatic camera switching for online classes through behavior analysis of professors and students.
Participated on behalf of the laboratory and achieved 5th place out of 64 teams in the Multi-View 3D Visual Grounding track.
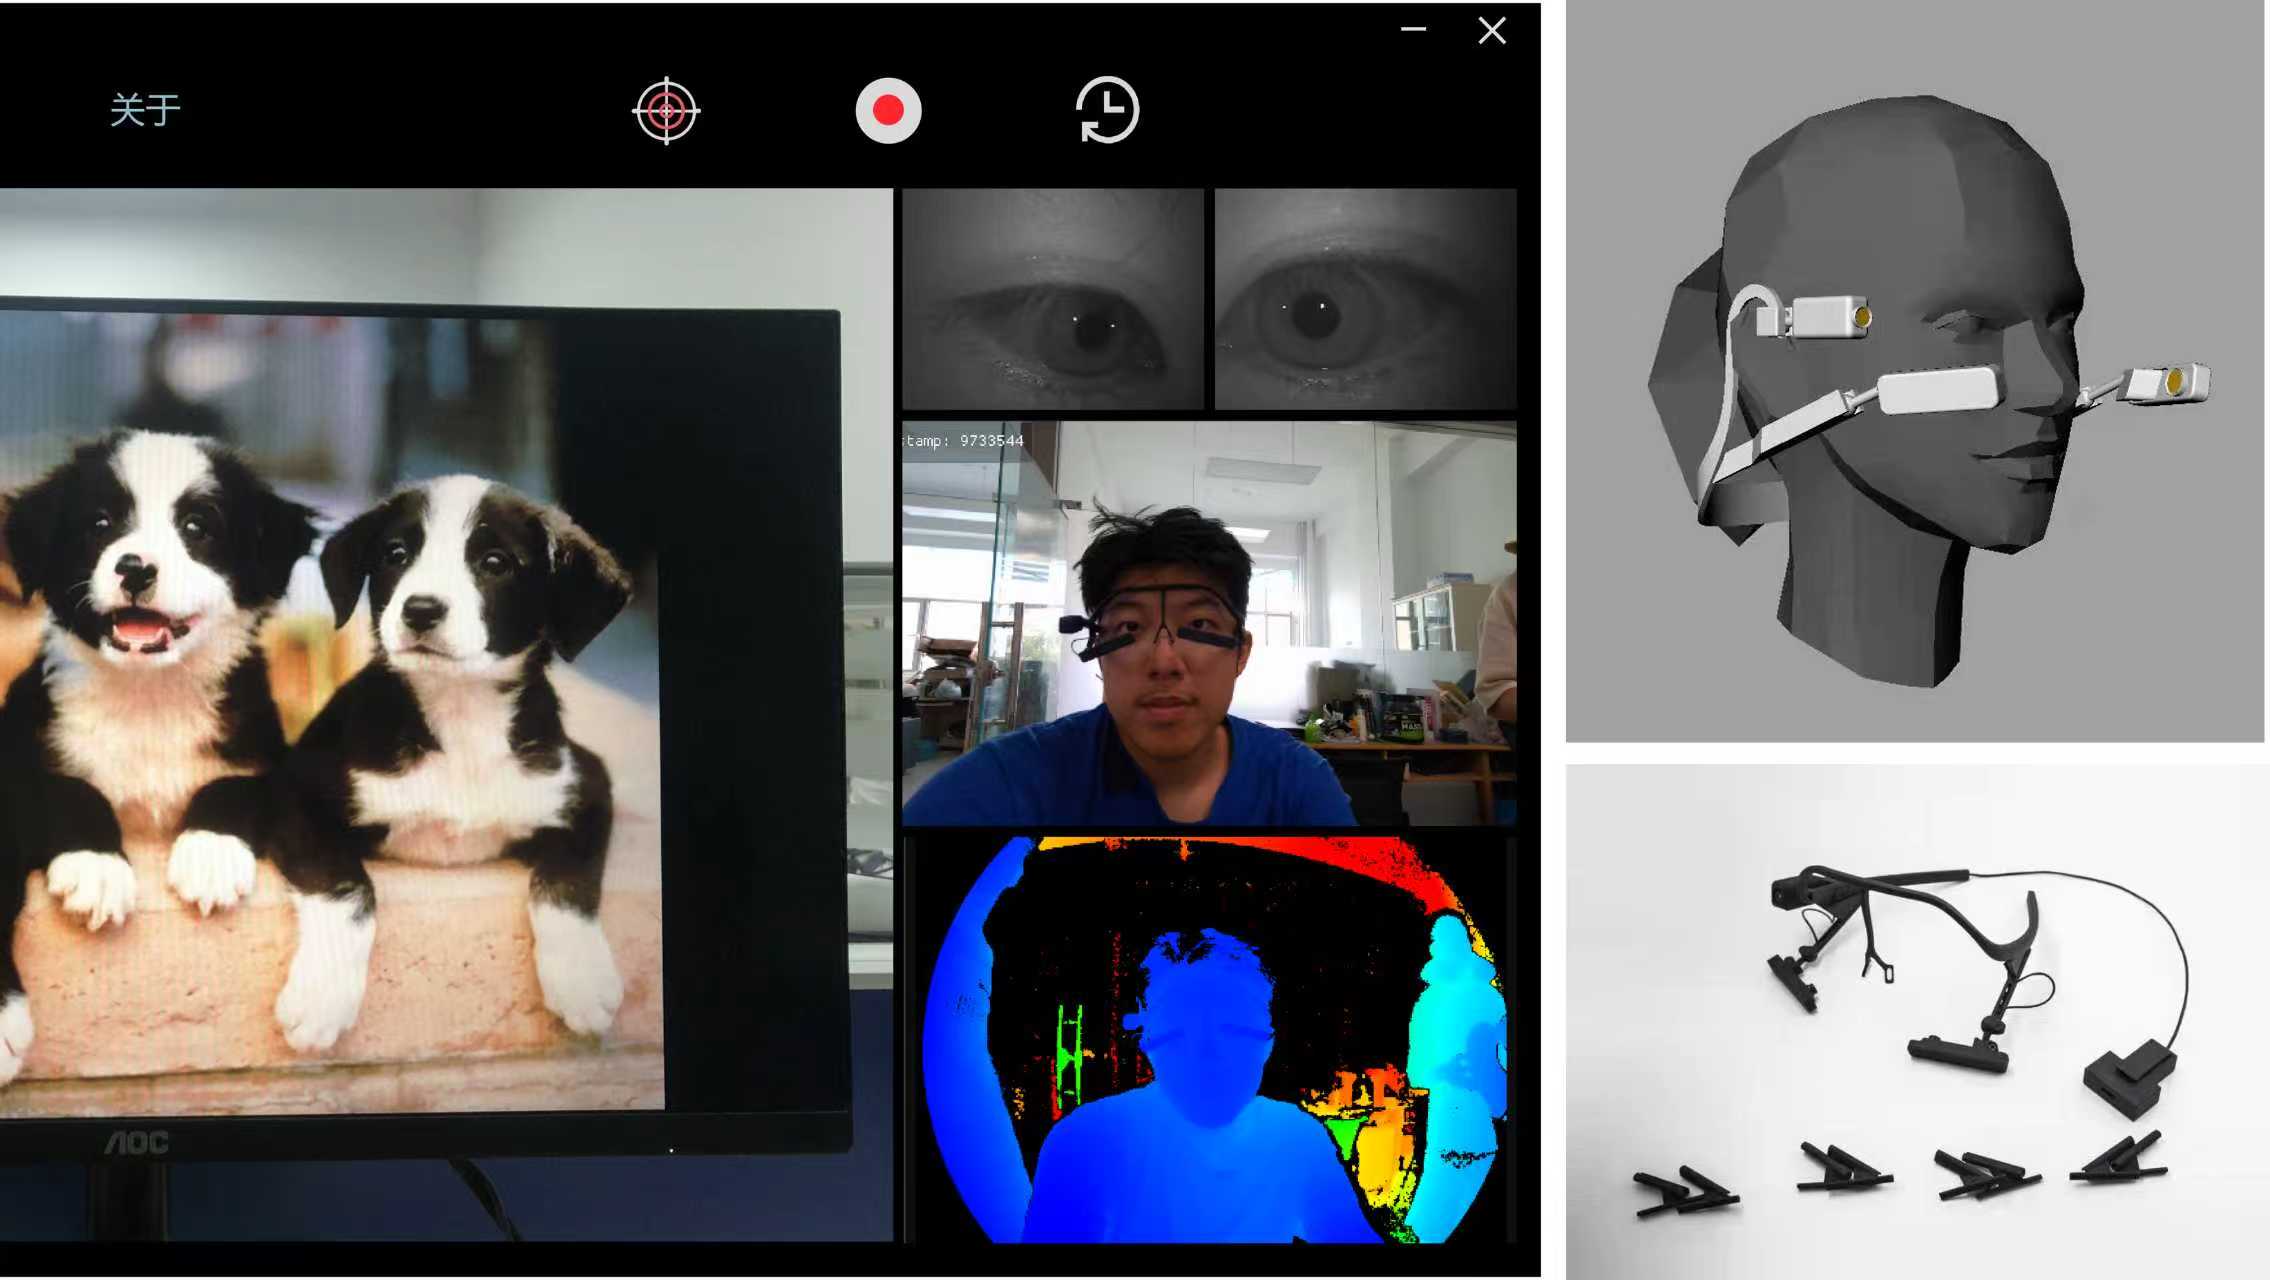
Desktop system for synchronized eye-movement and facial-expression acquisition
Website for a multimodal emotion dataset.